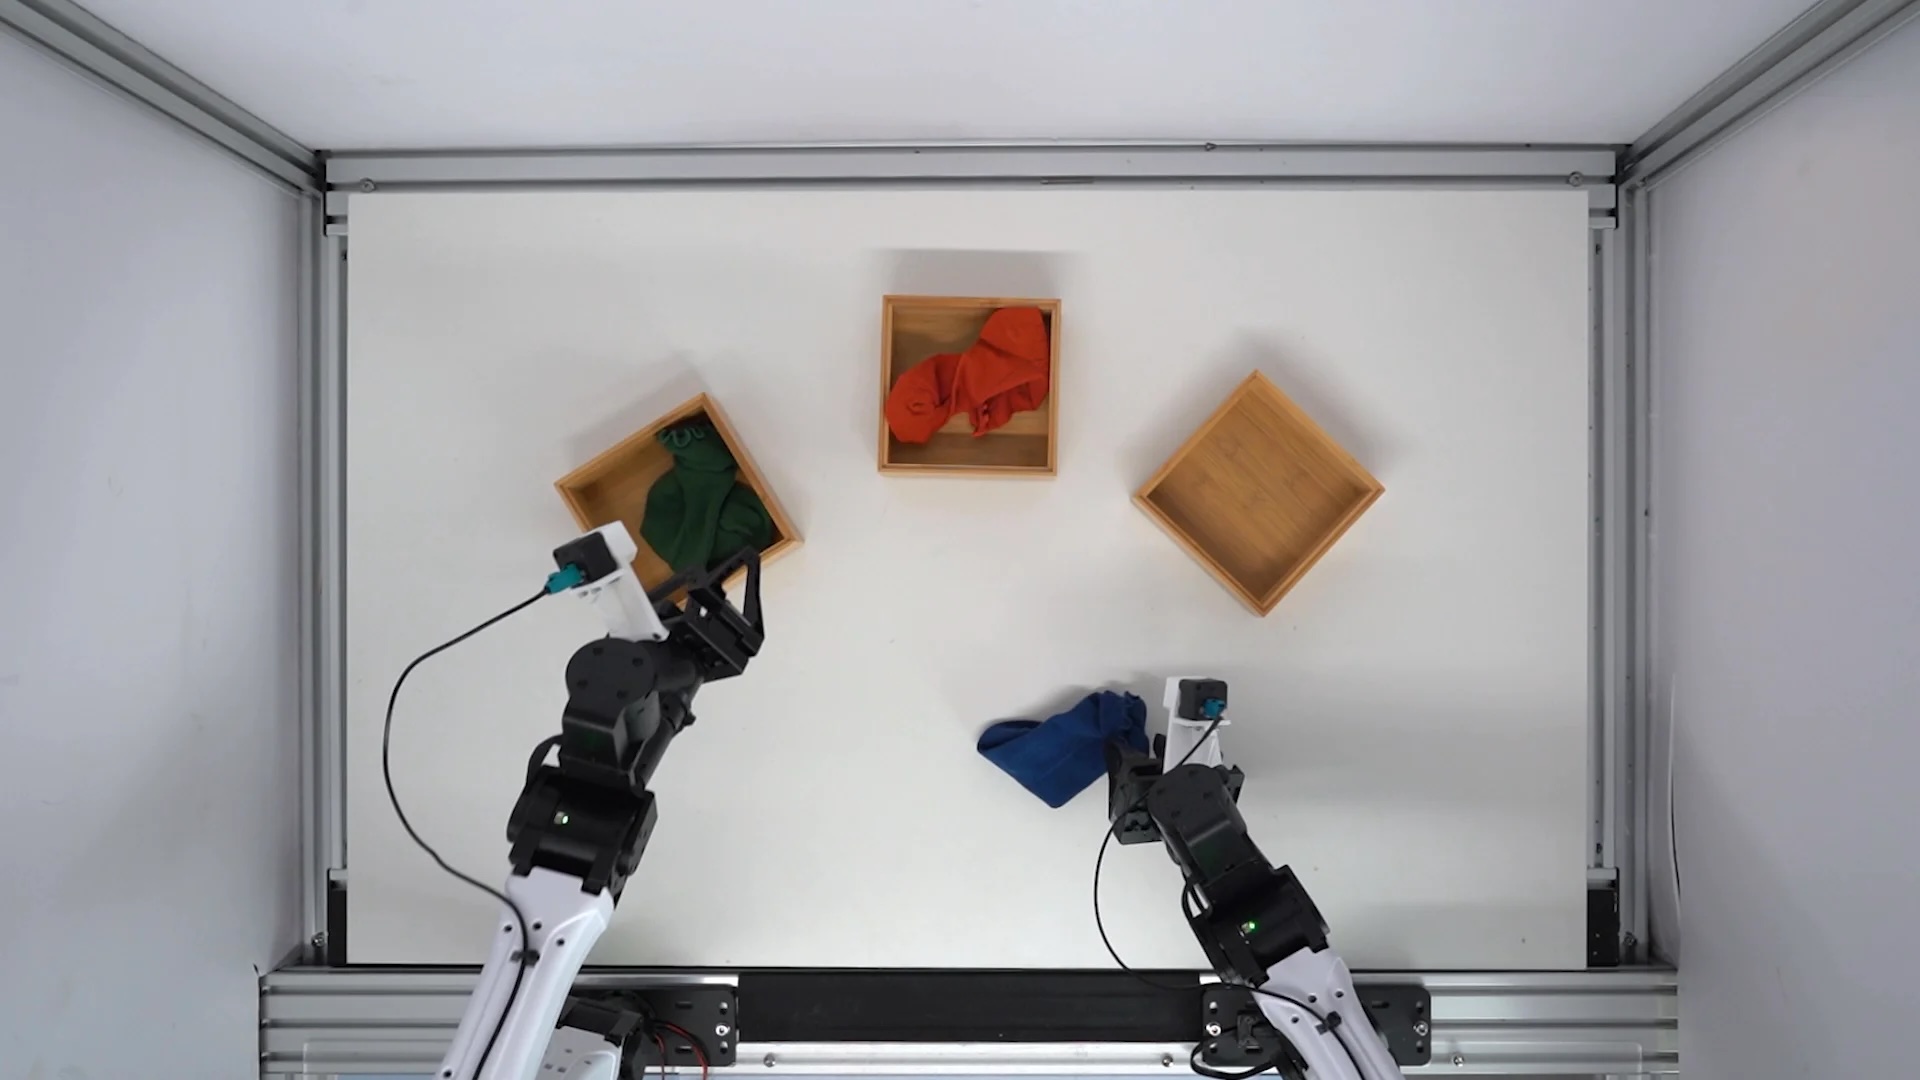
Runway has released Praxis-1, its robot control model, with open weights and source code under the Apache 2.0 license, which allows commercial use. The company first introduced the model in late September and had given access only to select partners until now. Runway published a research report alongside the release with its own performance tests.
Praxis-1 takes in camera images, text instructions, and information about a robot's position. It predicts how the environment will change and calculates the robot movements to match. As new camera frames arrive, the model adjusts its control continuously. Runway calls it a World Action Model.
The model builds on a video model that learned how objects move and interact from ordinary footage. Runway then fine-tuned it with videos of human actions and robot data. According to the article, this could reduce the need for expensive robot-specific datasets, though the article notes it is still unclear whether the approach needs less robot data overall than comparable models.
Since September, Standard Bots, Noble Machines, and Ultra have tested Praxis-1 on a humanoid robot, an industrial robot arm, and a dual-arm warehouse robot. To adapt the model to a Franka robot arm, Runway used about 277 hours of recordings from the public DROID research dataset. For a dual-arm robot, the company used between